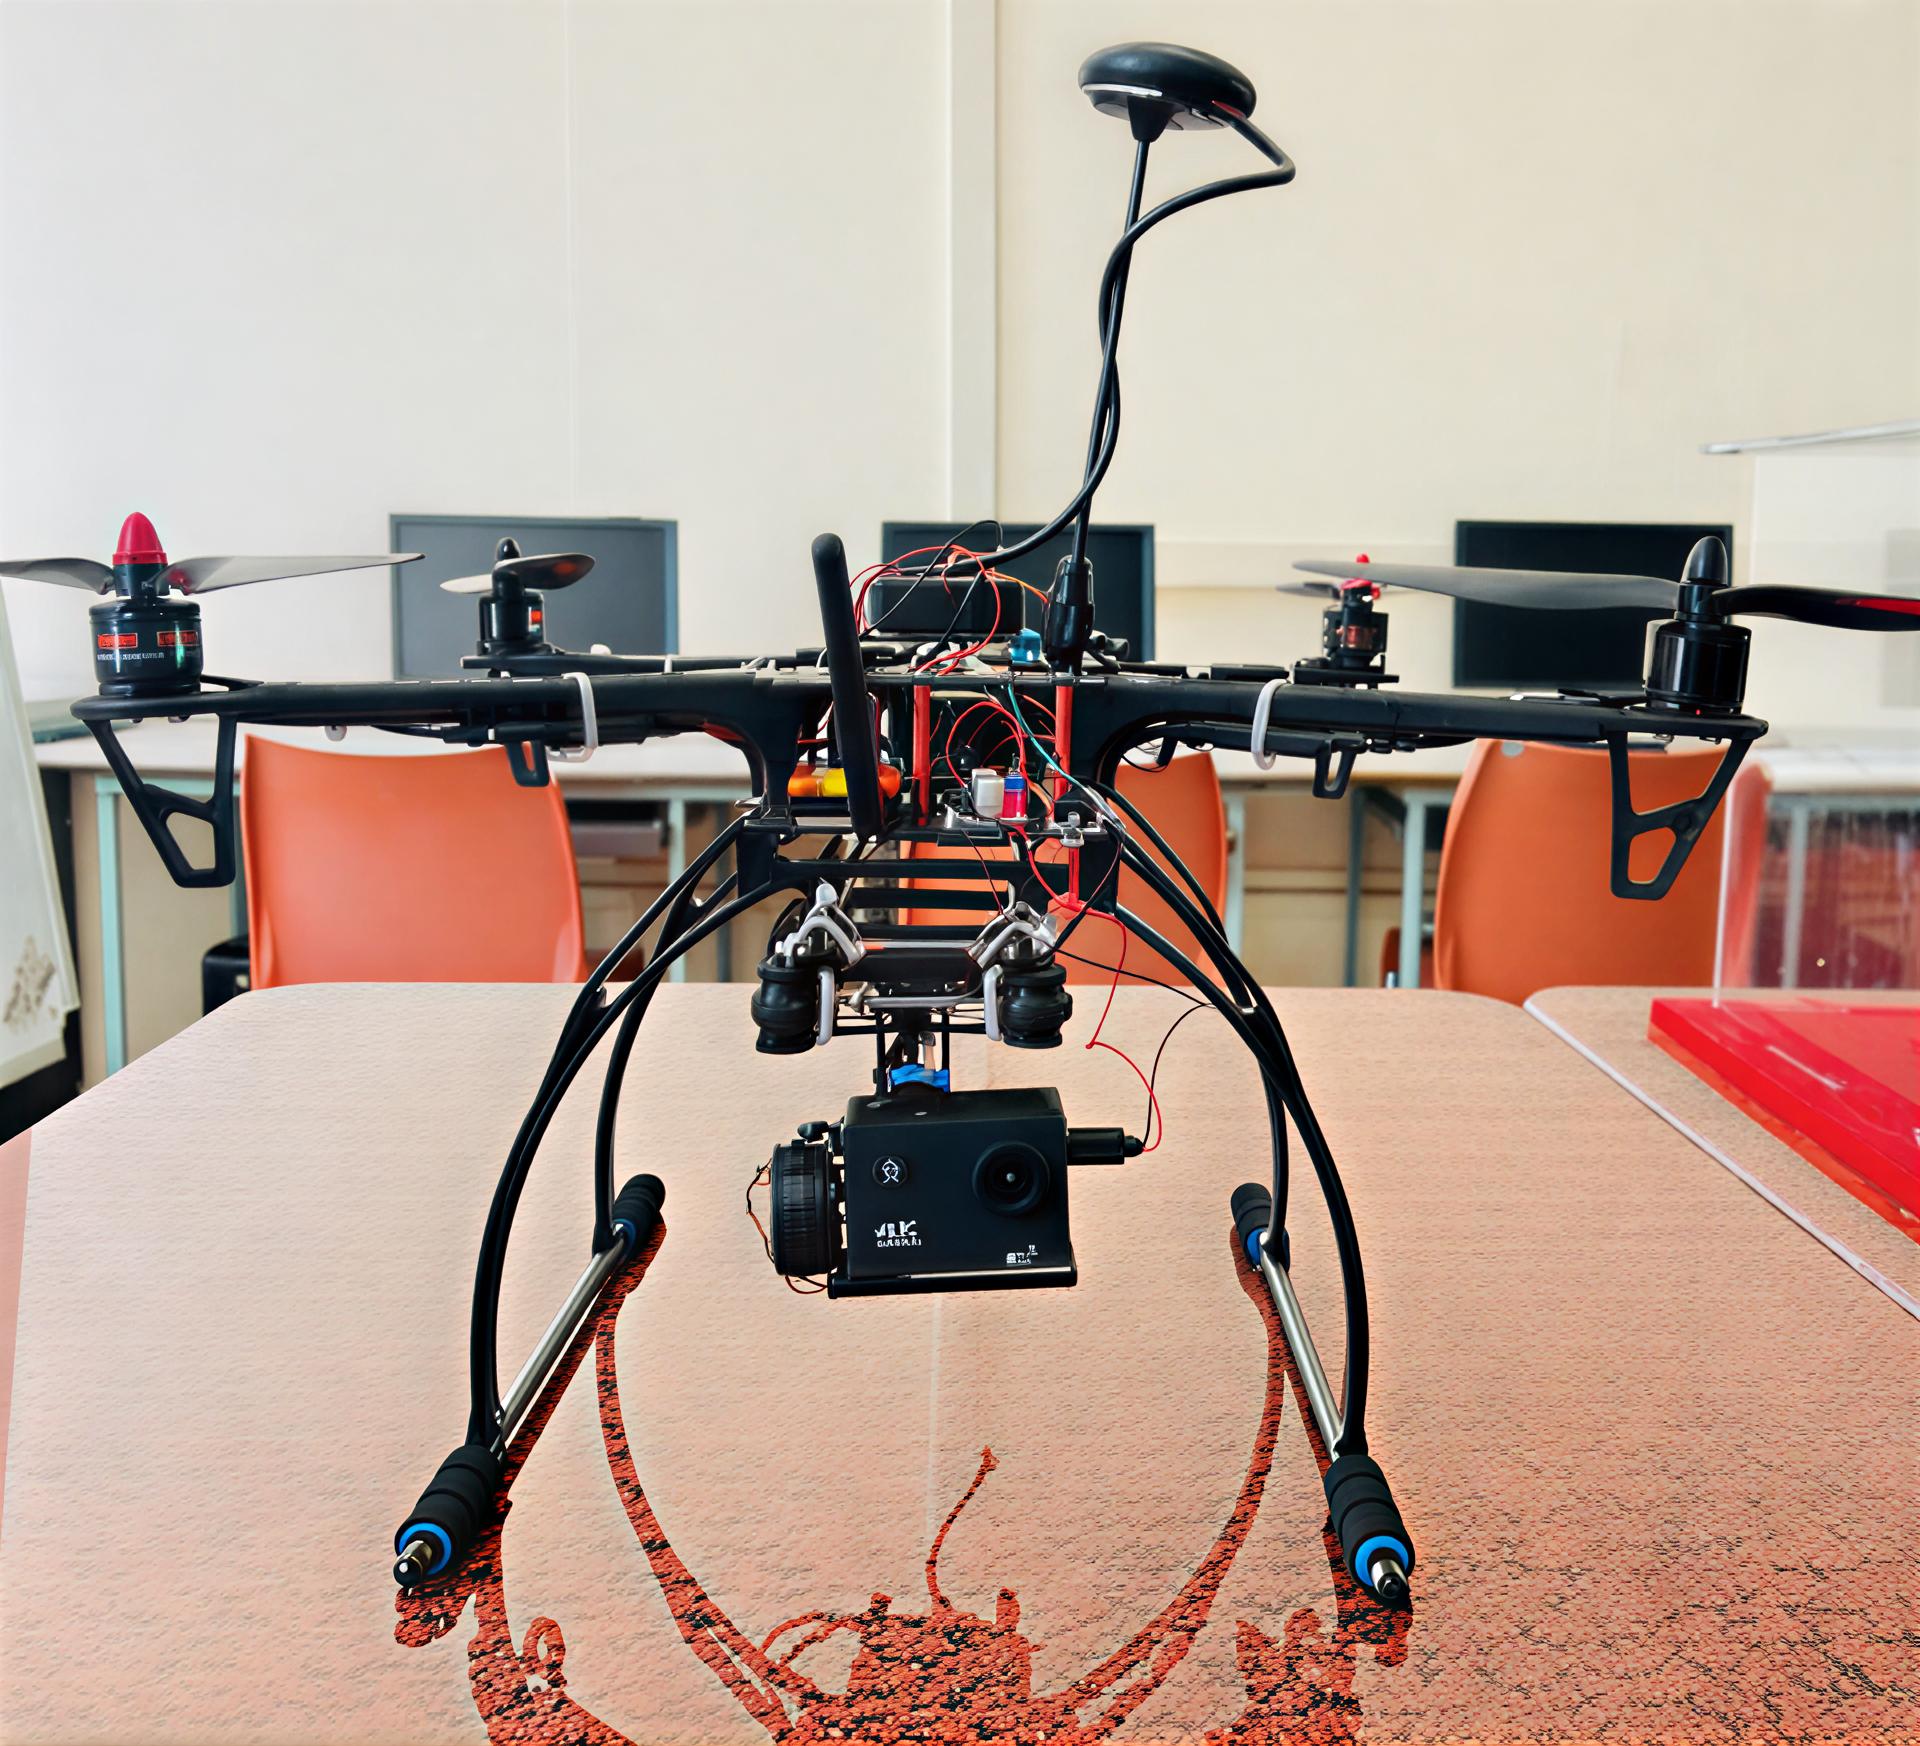
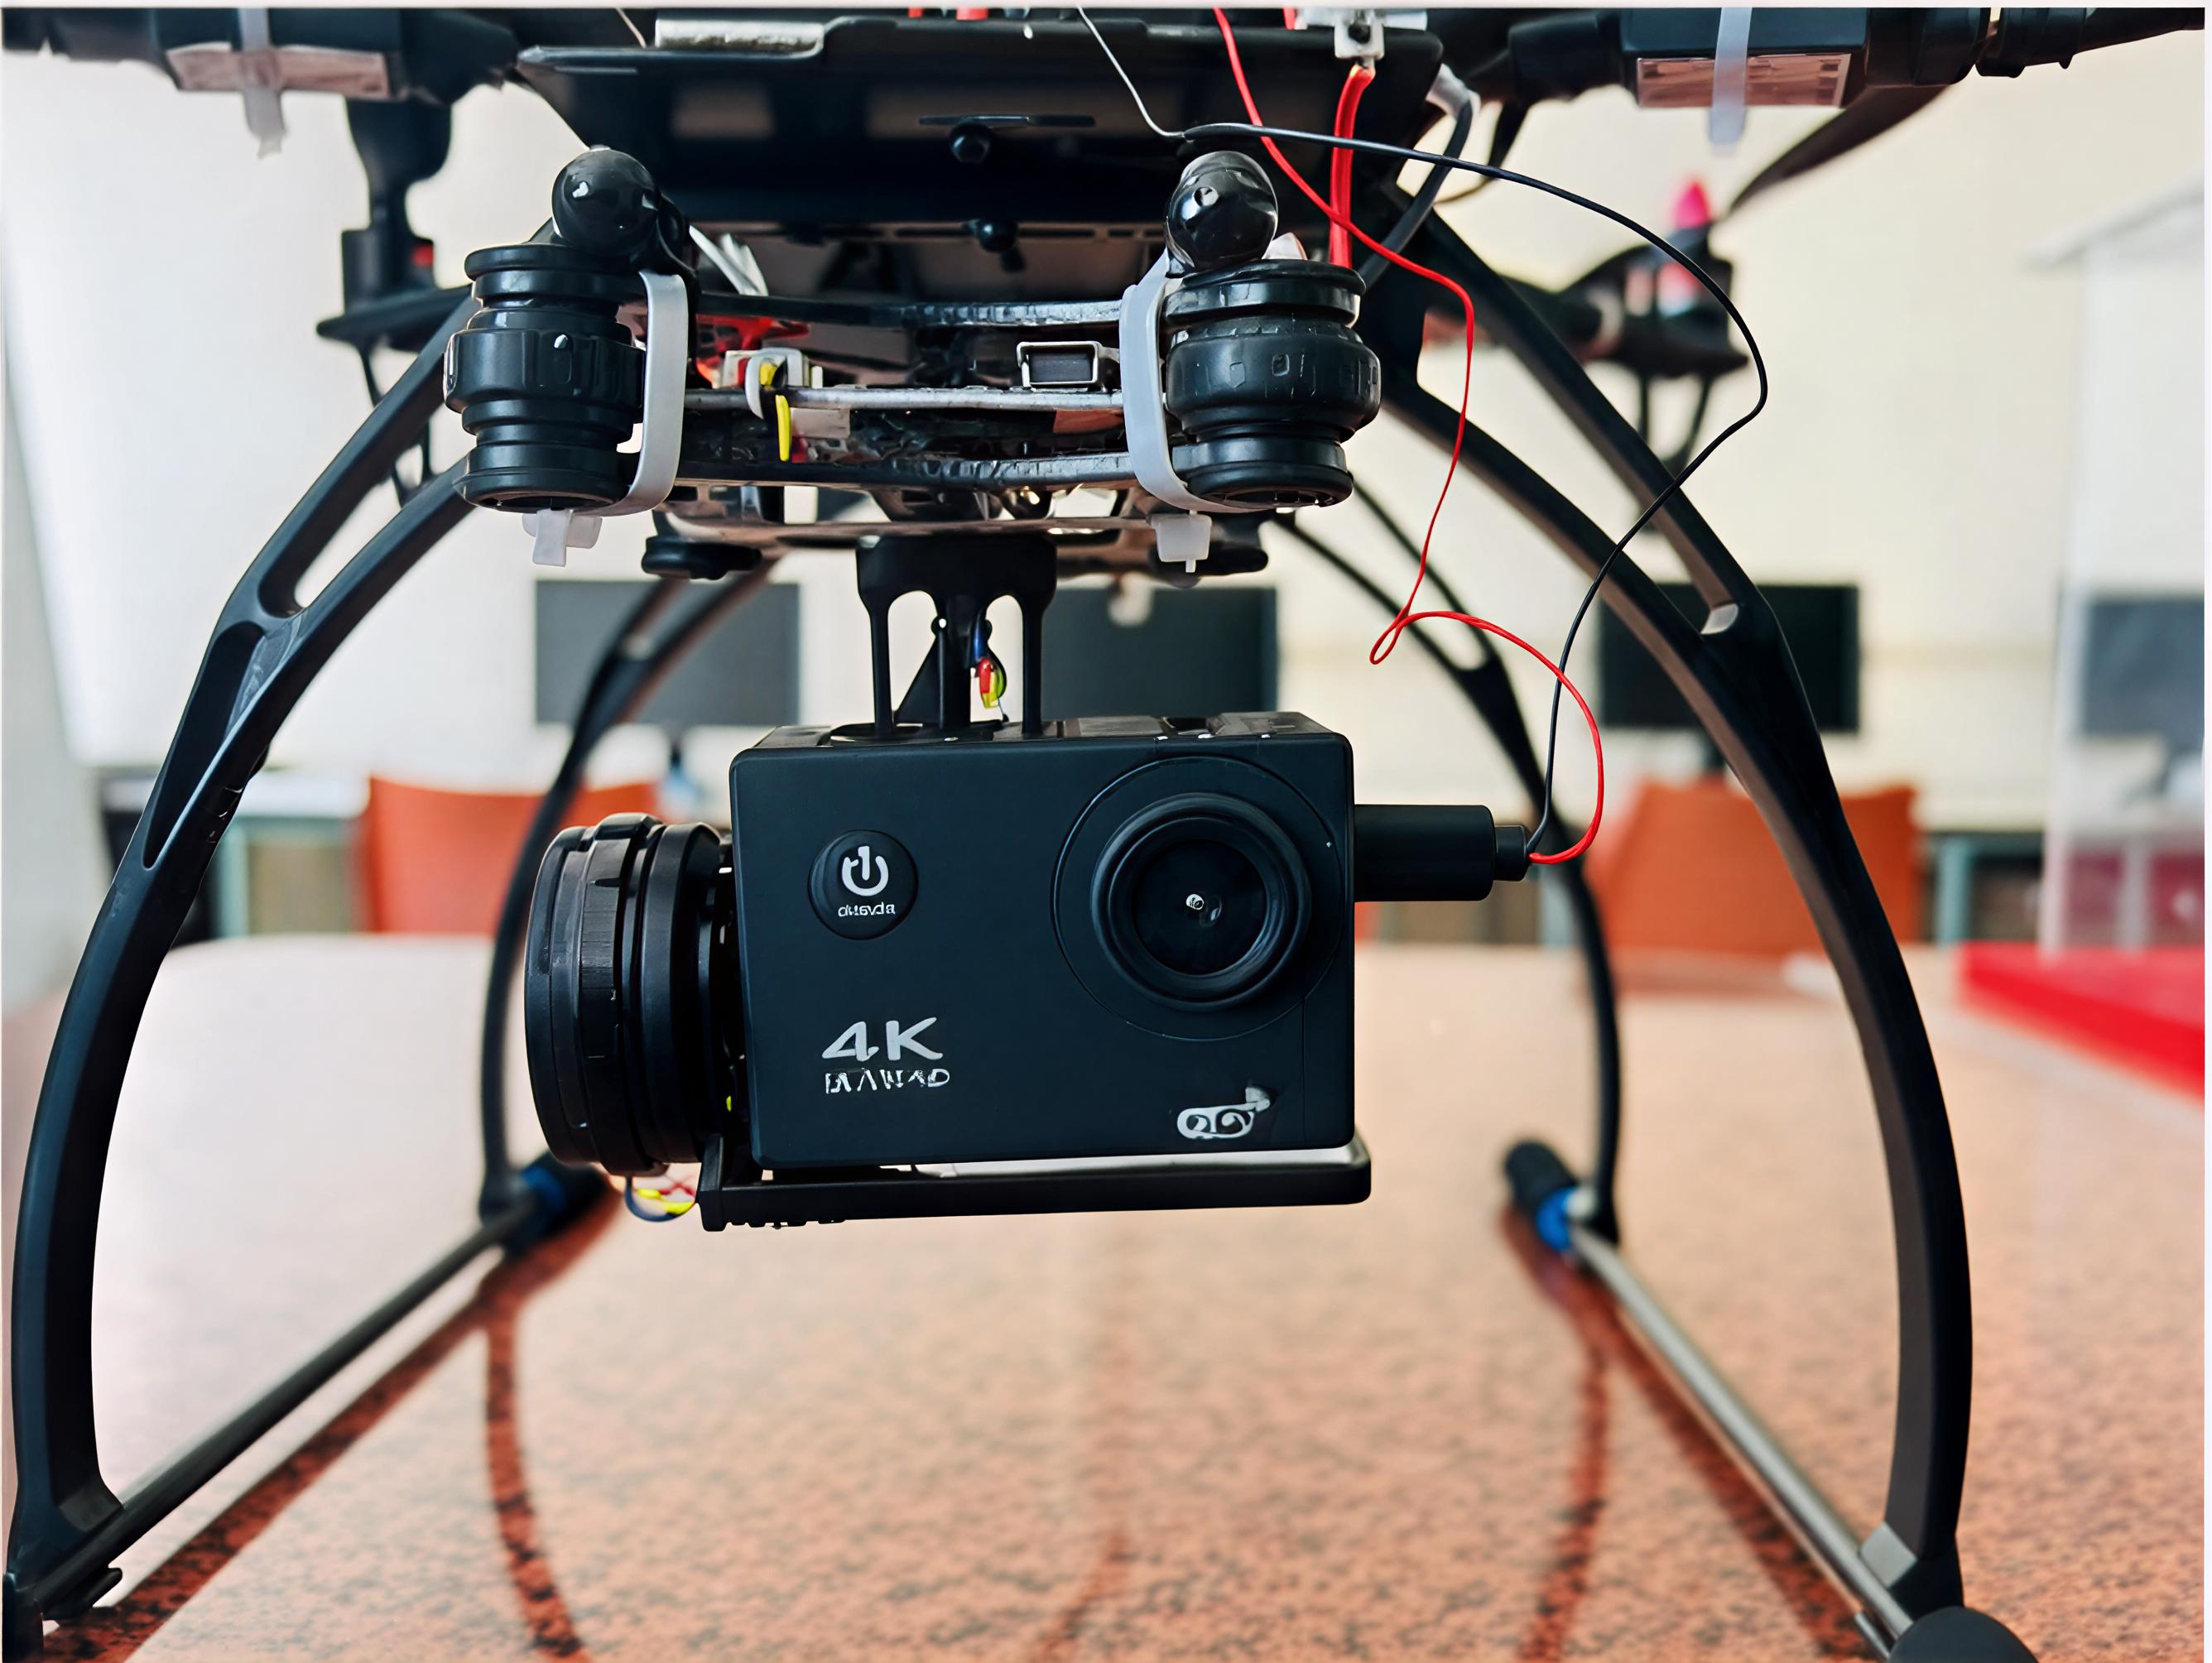
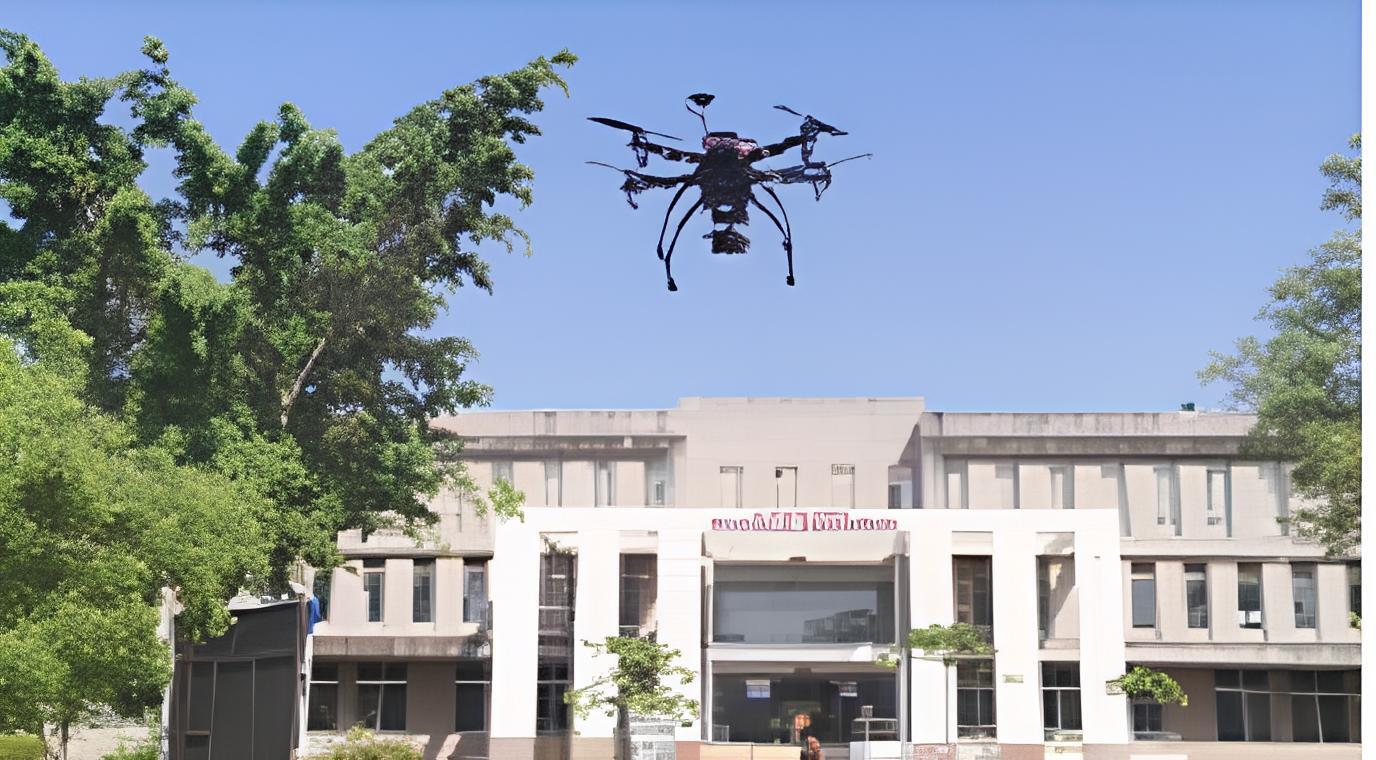
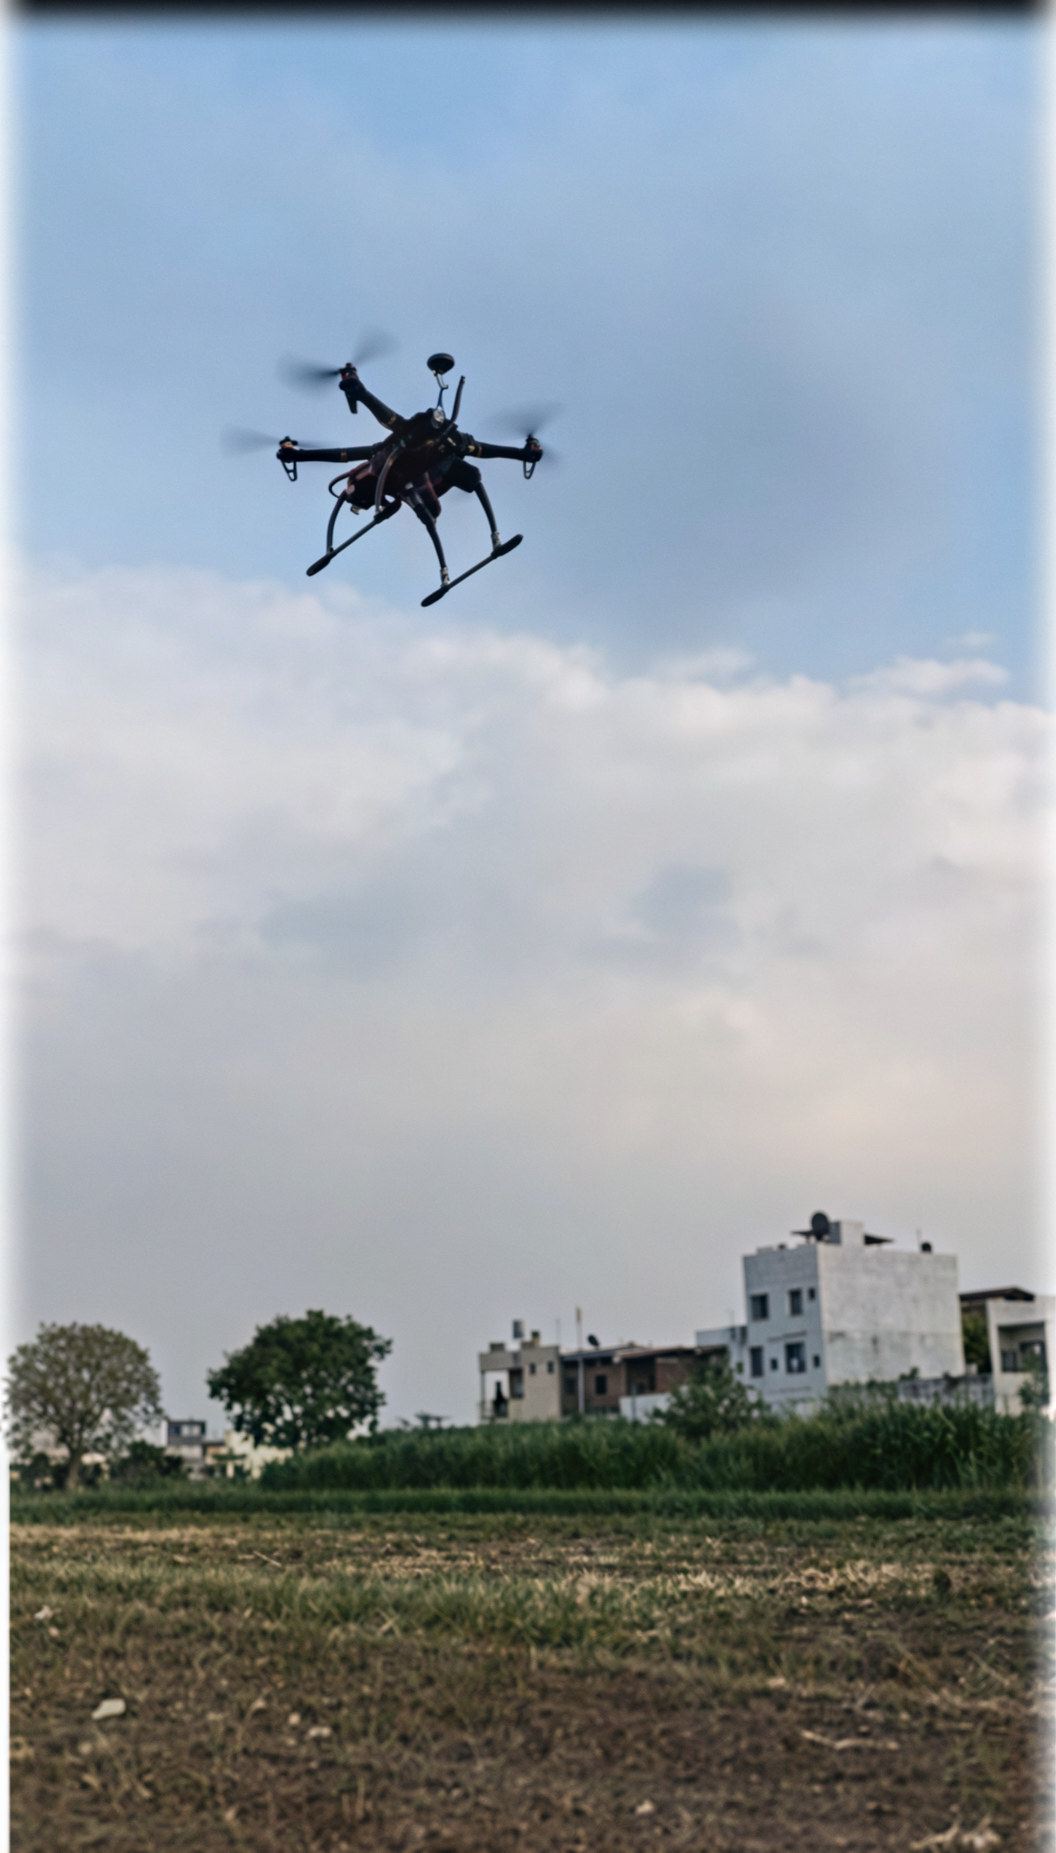
Project Overview
This quadcopter drone was designed as our
final year engineering project using Pixhawk 2.4.8
Flight Controller with GPS Navigation,
Telemetry Communication,
Brushless Motors,
LiPo Battery and a 2-Axis Camera Gimbal.
Key Features
🛰️
GPS Navigation
Autonomous waypoint navigation with accurate positioning.
🎥
2-Axis Gimbal
Stable aerial imaging by minimizing camera vibrations.
⚡
BLDC Motors
High-efficiency brushless motors for stable flight.
🛩️
Pixhawk Controller
Open-source flight controller supporting autonomous missions.
📡
Telemetry
Real-time monitoring and communication between drone and ground station.
🔋
LiPo Battery
Lightweight high-capacity battery providing long flight duration.
Project Report
View the complete project report including
hardware design, block diagram, methodology,
implementation and testing.
View Report
Source Code
Explore the project source code,
documentation and implementation details
on GitHub.
Open GitHub